Automated insect detection has emerged as a cornerstone technology for integrated pest management in commercial greenhouse horticulture, where continuous and accurate counts of both pests and beneficial biocontrol organisms are required to schedule targeted interventions and curtail broad-spectrum chemical treatments. In a recent engineering study published in Smart Agricultural Technology, researchers Lennart Jütte, Kai Kaminski, Maximilian Löwen, Merve Wollweber, Rainer Meyhöfer, Elisa Wendisch, Tammo Ripken, and Hendrik Sandmann demonstrated that a lightweight object detector trained entirely on synthetic three-dimensional renders can detect real greenhouse insects on an active light trap without relying on manual image annotation. Standard deep learning architectures such as single-stage YOLO detectors typically demand thousands of laboriously annotated images that closely reflect the operational optics of the target environment. However, collecting and labeling such datasets poses severe practical obstacles in horticultural settings, where target insects occur seasonally, span sub-millimeter scales, and appear as dark silhouettes under the specialized backlit geometry of automated optical traps.
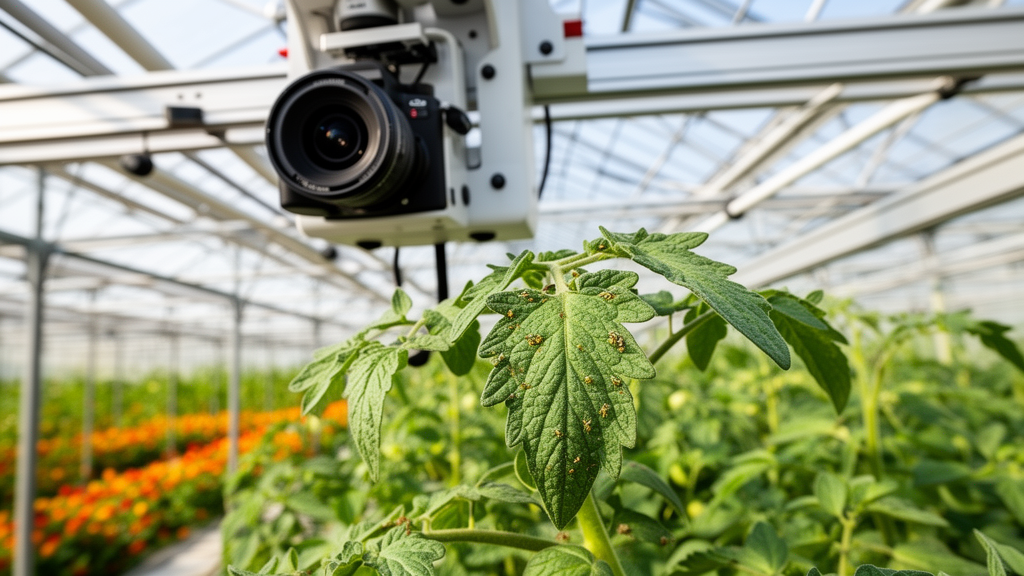
The optical configuration evaluated by the team was dictated by an autonomous light trap designed not merely as a passive counting instrument, but as an active, closed-loop detect-and-treat platform. Within this hardware assembly, flying insects are lured onto an actively illuminated light-emitting diode panel, where they are identified and localized in situ before being targeted by an onboard neutralizing laser module. Because shutting down the panel to photograph incoming insects under conventional ambient lighting would extinguish the behavioral stimulus holding them on the surface, the trap must image specimens directly against bright bottom illumination. Under these conditions, insects appear almost exclusively as low-contrast, silhouette-dominated forms stripped of their characteristic body coloration, rendering manual bounding-box annotation difficult and prone to fatigue even for experienced entomologists. Furthermore, because the ultimate operational objective is to guide a focused laser beam with a five-millimeter spot diameter to neutralize target pests, the primary functional requirement for the vision system is reliable object presence and accurate centroid localization rather than millimeter-tight bounding-box contours.
To bypass the burdensome requirement for real labeled images, the investigators devised a five-stage synthetic generation pipeline that synthesizes training frames from ordinary photographs. The workflow begins with a small library of ten high-resolution reference photographs per species gathered from the citizen-science platform iNaturalist and biocontrol suppliers Koppert and Royal Brinkman. Each photograph was processed through Meta’s SAM 3D foundation model to reconstruct a distinct, textured three-dimensional mesh, capturing individual morphological differences such as resting postures and wing angles. Because image-to-3D algorithms frequently struggle with thin biological structures, reconstructed meshes were manually screened for topological defects, discarding one defective model per species due to broken antennae or missing legs. The remaining nine models per species were normalized, scaled to realistic physical dimensions in millimeters, and procedurally populated across a virtual twin of the physical trap inside Blender 5.0 using Geometry Nodes and Poisson-disk spatial sampling to avoid unrealistic physical overlaps.
Realistic rendering and automated label extraction were achieved through multi-pass ray tracing within Blender’s Cycles engine, executed headlessly via its Python interface. Each scene was rendered inside an environment mapped with the Abandoned Greenhouse high-dynamic-range illumination map to simulate ambient surroundings, while the simulated panel bottom-lit the insects using randomized combinations of four discrete spectral channels: 385-nanometer ultraviolet, 465-nanometer blue, 530-nanometer green, and 590-nanometer yellow light. Concurrently, the engine generated a perfectly aligned, lighting-independent segmentation mask using Arbitrary Output Variables, where insects and background surfaces were rendered as solid emissive colors. An OpenCV script subsequently binarized these masks at a grayscale threshold of 150, applied a five-by-five elliptical dilation kernel to preserve faint antennal contours, filtered noise artifacts below twenty pixels, and extracted normalized YOLO bounding boxes. Fixed 256-by-256 pixel crops were extracted around insect centroids, mirroring the operational cropping strategy of the physical trap, which identifies localized movement through real-time inter-frame difference imaging.
The study focused its primary quantitative evaluations on four insect species central to greenhouse biological control: the greenhouse whitefly Trialeurodes vaporariorum, its specialized parasitoid Encarsia tricolor, the generalist predatory mirid bug Macrolophus pygmaeus, and an outgroup parasitoid of leafminers, Dacnusa sibirica. To rigorously benchmark the pipeline, the researchers assembled a held-out ground-truth validation set using physical hardware comprising a 16.1-megapixel Basler camera with a Sony IMX542 sensor and an eight-millimeter fixed lens operating at a 250-millimeter working distance. Pure single-species cohorts were released into a sealed enclosure over the trap to record one thousand frames per species with automated ground-truth labeling, resulting in a balanced 400-frame test set alongside pools of real training data. Detection was executed using an anchor-free YOLO26n architecture initialized from COCO-pretrained weights and trained across one hundred epochs with Ultralytics, AdamW optimization, and standard photometric augmentations on an NVIDIA RTX 4070 Super graphics processing unit.
Empirical testing compared a real-data baseline trained on 3200 real images (Model A), a purely synthetic model trained on 3200 virtual renders (Model B), and a hybrid model trained on the combined set of 6400 frames (Model C). Evaluated on the held-out real dataset, Model B achieved a mean average precision at an IoU threshold of 0.50 (mAP50) of 0.786, alongside an overall precision of 0.796 and a recall of 0.748. Because the COCO initialization contains no insect categories, the network’s ability to localize real insects approaching eighty percent accuracy was directly attributable to features acquired from synthetic renders. In contrast, under the stringent mAP50–95 metric, which averages performance across overlap thresholds up to 0.95, Model B attained only 0.367, whereas Models A and C achieved identical scores of 0.814. This discrepancy highlighted that while synthetic training reliably teaches the detector to find insects, differences in sensor noise and label padding prevent pixel-tight bounding-box boundaries.
At the individual species level, detection accuracy under the stricter mAP50–95 metric varied widely depending on physical specimen size and visual contrast. Model B scored 0.50 on Macrolophus pygmaeus, 0.39 on Encarsia tricolor, 0.34 on Dacnusa sibirica, and 0.23 on Trialeurodes vaporariorum, remaining substantially below Model A’s corresponding marks of 0.81, 0.69, 0.90, and 0.85. The real baseline itself struggled most on the minute, low-contrast parasitoid Encarsia tricolor, which measures only 0.6 to 0.8 millimeters in length and spans roughly seven pixels across the camera sensor at the trap’s optical resolution of 0.083 millimeters per pixel. For this species and Macrolophus pygmaeus, hybrid training in Model C yielded slight numerical improvements over Model A (0.72 versus 0.69, and 0.82 versus 0.81, respectively). However, because these differences were of the magnitude of single-run experimental variance, the authors characterized synthetic data assistance in well-represented classes as an exploratory hypothesis rather than an established finding.
To investigate low-data regimes, the authors conducted an admixture sweep (the Model D series) by fixing a modest seed of 320 real images—ten percent of the full baseline—and progressively supplementing it with synthetic renders from zero to 2880 images. The seed of 320 real images alone achieved an aggregate mAP50–95 of 0.795, coming within 0.019 of the 3200-image baseline despite utilizing ninety percent fewer real photographs. Introducing moderate quantities of synthetic images maintained stable overall mAP50 and recall while incrementally increasing precision from 0.913 to 0.931. However, when synthetic images constituted ninety percent of the mixture (320 real plus 2880 synthetic frames), aggregate mAP50–95 dropped to 0.768, driven by a sharp decline in Encarsia tricolor from 0.69 down to 0.60. A Friedman test across admixture levels indicated a statistically significant effect across the four species blocks, suggesting that excessive synthetic volume can overwhelm the real-world sensor noise and lens artifacts needed by backpropagation.
Confusion matrix analyses further illuminated critical behavioral trade-offs between coarse object localization and fine taxonomic discrimination. In the four-species real test set, Model B directed 386 of the 400 test insects into an insect category, proving that its recall deficit was overwhelmingly driven by classification errors rather than missed targets. Its primary confusion pattern involved Dacnusa sibirica, where 57 of 100 individuals were erroneously identified as Macrolophus pygmaeus. More critically for automated greenhouse management, Model B misclassified 19 out of 100 beneficial Encarsia tricolor parasitoids as pest whiteflies, while simultaneously labeling 40 out of 68 background false alarms as whiteflies. Because real-trained Models A and C misclassified zero beneficial insects as whiteflies, deploying purely synthetic models in autonomous lethal laser traps would risk exterminating released biological control agents, demonstrating that high-stakes autonomous interdiction still demands either safeguard protocols or supplemental real training data.
The researchers articulated several hardware, optical, and methodological boundaries that contextualize their results and delineate future work. The evaluation relied on single training runs without random-seed replication, while ground-truth partitioning was conducted at the image level rather than the individual specimen level, meaning the same insect could appear in both training and test frames. Optically, the resolution limit is governed by the five-megapixel rating of the eight-millimeter lens over its image circle rather than the 16.1-megapixel sensor, making optical magnification the principal bottleneck for resolving sub-millimeter parasitoids. Furthermore, while the compact YOLO26n architecture is specifically targeted for edge deployment on an onboard NVIDIA Jetson Orin Nano computer, actual on-device latency and processing frame rates remain unmeasured. Nevertheless, the study confirms that procedural physics-based rendering coupled with image-to-3D generation can rapidly bootstrap operational insect monitoring for emerging greenhouse species without waiting out seasonal collection windows.
Subject of Research: Procedural synthetic training data for automated greenhouse insect detection and laser pest control
Article Title: Synthetic training data from a virtual light trap enables insect detection for greenhouse pest management without manual annotation
Article References: Jütte, L., Kaminski, K., Löwen, M., Wollweber, M., Meyhöfer, R., Wendisch, E., Ripken, T., & Sandmann, H. (2026). Synthetic training data from a virtual light trap enables insect detection for greenhouse pest management without manual annotation. Smart Agricultural Technology, 15, Article 102723. https://doi.org/10.1016/j.atech.2026.102723
Image Credits: AI Generated
DOI: 10.1016/j.atech.2026.102723
Keywords: integrated pest management, synthetic training data, YOLO26n, procedural rendering, Blender Cycles, domain randomization, light trap monitoring, laser pest control, Trialeurodes vaporariorum, Encarsia tricolor, Macrolophus pygmaeus, Dacnusa sibirica, SAM 3D, sim-to-real transfer, NVIDIA Jetson Orin Nano, edge computing, greenhouse horticulture
News Source: Gavin Prescott. (November 13, 2026). Synthetic Training Data Enables Greenhouse Insect Detection Without Manual Annotation. Scienmag.