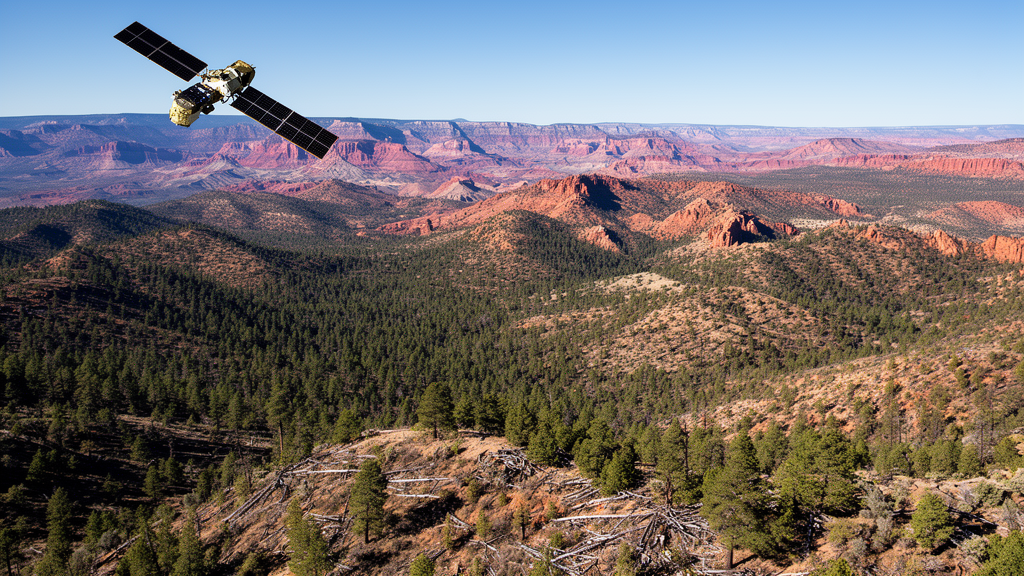
Ecologists and forest managers face persistent hurdles when attempting to quantify how structural fuel continuity shifts across complex southwestern forest landscapes over time. In a research study published in Fire Ecology, an environmental research team developed 4D-FUELS, a semi-automated remote sensing framework that integrates airborne light detection and ranging data with orbital radar and optical observations to produce ten-meter resolution forest structure and fuel maps on an annual basis. While forest thinning treatments and prescribed burns are regularly deployed to break vertical and horizontal fuel continuity, land stewardship agencies routinely encounter significant statutory and operational monitoring gaps due to the scarcity of dynamic, regularly updated spatial datasets.
The developmental testbed for the 4D-FUELS platform centered upon the upper Rio Grande watershed and adjacent forested zones spanning southern Colorado and northern New Mexico, encompassing roughly 4.16 million hectares of land area with approximately 3.75 million forested hectares. This heterogeneous region spans elevations from 1500 to 4000 meters above sea level and exhibits substantial environmental gradients, featuring mean annual precipitation between 200 and 1000 millimeters and July maximum temperatures ranging from 15 to 32 degrees Celsius. Forest composition across the study area includes dominant pinyon-juniper woodlands representing about 45 percent of the forested acreage, Douglas-fir stands comprising roughly 22 percent, ponderosa pine accounting for 14 percent, high-elevation spruce-fir covering 9 percent, quaking aspen stands occupying 6 percent, and woodland hardwoods such as Gambel oak making up 4 percent. Land jurisdiction is divided among federal public lands comprising 61 percent, private landowners holding 32 percent, and tribal lands representing 6 percent, creating a diverse matrix of management practices, historical mechanical thinning, prescribed burning, insect outbreaks, and variable wildfire disturbances.
Point clouds are filtered to eliminate atmospheric noise, ground points are classified, and elevations are normalized to height above ground surface using the specialized LasR software library. The analytical system constructs digital terrain models from ground returns and compiles one-meter canopy height models, which are then aggregated to ten-meter grid cells based on maximum per-cell return height to determine overstory canopy height. Stratified vegetative cover fractions are calculated from height-binned return counts, computing total canopy cover above one meter, upper-canopy cover above five meters, sub-canopy cover between two and five meters relative to sub-five-meter returns, and surface fuel cover between one and two meters relative to sub-two-meter returns. Individual tree crowns are delineated using local-maxima treetop detection followed by variable-window segmentation calibrated across dense and open forest conditions.
Crown-level metrics derived from the airborne point clouds are scaled to ten-meter raster pixels, providing training data across fourteen distinct vegetation structure and fuel load attributes. Stand density is computed as stems per hectare, while individual stem diameters at breast height are estimated from delineated crown heights using species-group exponential models calibrated against regional Forest Inventory and Analysis plot records. These predicted diameters are summarized at ten-meter cell resolution into quadratic mean diameter and arithmetic mean diameter, while crown base height is extracted using the cloud2trees and LadderFuelR packages to compute stand canopy base height. To estimate standing fuel loads without fitting ad hoc equations, researchers implemented the National Scale Volume and Biomass equation system using regional allometric coefficients, partitioning crown wood volume, aboveground biomass, woody biomass, foliage biomass, and total carbon weight. To minimize taxonomic ambiguity during biomass calculation, plot-level dominance across regional national inventory surveys was used to assign single representative timber species to each overarching forest-type category.
To transition from discrete airborne survey boundaries to continuous regional mapping, the system assembles composite satellite predictor variables within the Google Earth Engine cloud computing platform. Radar predictors incorporate vertical-vertical and vertical-horizontal backscatter coefficients alongside the computed vertical-vertical to vertical-horizontal polarization ratio, which combine with thirteen Sentinel-2 spectral bands to generate a standardized sixteen-variable predictor stack. To enforce seasonal consistency across divergent terrain, the pipeline calculates median composite values over a snow-free, leaf-on temporal window extending from June through September. Land cover masks derived from the National Land Cover Database tree canopy cover product, filtered at a baseline ten percent canopy cover threshold, are applied to constrain statistical sampling and predictive inference exclusively to forested landscapes across the multi-million-hectare study domain.
Predictive modeling within Google Earth Engine employs an ensemble machine-learning architecture comprising two independent Random Forest models consisting of fifty decision trees each, whose final regression predictions are averaged. The workflow maintains fixed hyperparameter settings across every modeled attribute, configuring the random feature split parameter to the square root of total predictors, setting the sample bagging fraction to 0.6, and enforcing a minimum terminal leaf population of twelve samples. This architectural uniformity circumvents repetitive parameter tuning across divergent fuel metrics, allowing the complete sixteen-band satellite predictor stack to be computed once per target season and applied sequentially to all fourteen structure attributes. For each forest metric, model fitting relied upon an identical random training draw of 100,000 pixels extracted from the 2017 North Central New Mexico airborne lidar footprint, balancing algorithmic convergence against Earth Engine memory and task execution boundaries while taking approximately two hours per attribute to generate regional wall-to-wall maps.
Statistical evaluation followed a rigorous three-tiered framework comprising within-campaign cross-validation, same-year spatial validation across geographic boundaries, and multi-year temporal validation across independent lidar acquisitions. In within-campaign cross-validation using an independent sample of 20,000 withheld points from the 2017 North Central New Mexico dataset, predictive performance was highest for upper-canopy attributes, led by tree height with an R-squared of 0.60 and a root mean squared error of 4.74 meters, alongside canopy cover exhibiting an R-squared of 0.51 and an error of 12.49 percent. Intermediate statistical skill was documented for quadratic mean diameter with an R-squared of 0.45 and root mean squared error of 8.03 centimeters, wood volume with an R-squared of 0.35 and error of 1.55 cubic meters, and canopy base height yielding an R-squared of 0.33 with a 1.98-meter error. In contrast, explanatory skill was lowest for aboveground biomass at an R-squared of 0.25, sub-canopy cover and surface fuel cover each at 0.20, and stand density at 0.14.
Spatial validation conducted across southern Colorado within the Southern San Luis 2017 lidar campaign footprint revealed that absolute errors remained largely stable, though explained variance exhibited distinct attribute-specific sensitivity. However, stand density, sub-canopy cover, surface fuel cover, and aboveground biomass exhibited substantial drops in R-squared, accompanied by pronounced regression-to-the-mean tendencies where extreme high and low structural values were compressed toward training averages. Similarly, temporal validation applying models trained on 2017 lidar to 2019 satellite composites and testing against the South Central New Mexico 2019 lidar dataset sustained predictive skill for tree height with an R-squared of 0.55, canopy cover at 0.51, quadratic mean diameter at 0.42, volume at 0.33, and biomass at 0.28, but suffered sharp statistical degradation for lower-strata cover, tree density, and canopy base height.
Researchers demonstrated the real-world utility of the 4D-FUELS workflow by tracking landscape restructuring caused by the 2018 Ute Park Fire, an event that consumed 148.7 square kilometers in northern New Mexico. Differencing pre-fire 2017 and post-fire 2019 satellite-derived attribute layers across 1,365,894 burned ten-meter pixels revealed coherent, fire-induced shifts in structural metrics that matched expected burn patterns. Mapped tree density declined by an average of 72.3 stems per hectare, with 29.5 percent of burned pixels exhibiting absolute stem density drops exceeding 100 stems per hectare. Canopy cover decreased by an average of 18 percentage points, with 37.1 percent of the burned footprint showing reductions greater than 25 percentage points, while quadratic mean diameter exhibited an average decline of 4.49 centimeters, with 42.8 percent of pixels experiencing drops exceeding 5 centimeters. In unburned forested pixels surrounding the fire perimeter, differenced attribute distributions remained centered tightly near zero, verifying baseline temporal stability across undisturbed vegetation.
Independent field comparisons and analytical caveats emphasize that mapped products must be applied with careful consideration of structural uncertainty and sensor limitations. When lidar-derived individual tree metrics were evaluated against 95 field plots containing 2627 live measured stems across northern New Mexico, lidar segmentation identified only 998 stems within plot footprints, highlighting that smaller understory stems beneath dense overstory canopies frequently escape optical and laser detection. Furthermore, multi-step error propagation across crown segmentation, height-diameter allometry, and biomass equations compounds predictive uncertainty in lower-strata cover, stem density, and standing biomass pools. The authors emphasize that while upper-canopy products such as tree height and canopy cover exhibit strong transferability for immediate operational planning, lower-canopy attributes are best suited for landscape-scale screening rather than stand-level decisions, requiring localized field calibration or dedicated pre- and post-treatment plot validation before quantifying statutory compliance for forest fuels treatments or endangered species habitat conservation.
Subject of Research: Semi-automated annual mapping and monitoring of forest structure and wildland fuels using airborne lidar and Sentinel satellite imagery
Article Title: 4D-FUELS: a LiDAR-to-satellite system for mapping and monitoring forest structure and fuels
Article References: Vallet, L., Mast, C. N., Hurteau, M. D., Banerjee, S., Zald, H. S. J., Jones, G. M., & Francis, E. J. (2026). 4D-FUELS: a LiDAR-to-satellite system for mapping and monitoring forest structure and fuels. Fire Ecology, 22(1), Article 176. https://doi.org/10.1186/s42408-026-00605-1
Image Credits: AI Generated
DOI: 10.1186/s42408-026-00605-1
Keywords: 4D-FUELS, forest structure, wildland fuels, airborne lidar, Sentinel-1, Sentinel-2, Google Earth Engine, remote sensing, Random Forest, canopy cover, canopy base height, quadratic mean diameter, fuel continuity, wildfire monitoring, Ute Park Fire, fuel treatment planning, Three-Dimensional Elevation Program, forest management
News Source: Drew Townsend. (November 12, 2026). Satellite Workflow Maps Southwestern Forest Structure and Fuel Dynamics Annually. Scienmag.