• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Wednesday, November 11, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Improved Tornado Optimizer Matches Dijkstra Shortest Path in Robot Navigation Tests

by
November 11, 2026
in Technology
Reading Time: 2 mins read
0
Improved Tornado Optimizer Matches Dijkstra Shortest Path in Robot Navigation Tests

Improved Tornado Optimizer Matches Dijkstra Shortest Path in Robot Navigation Tests

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

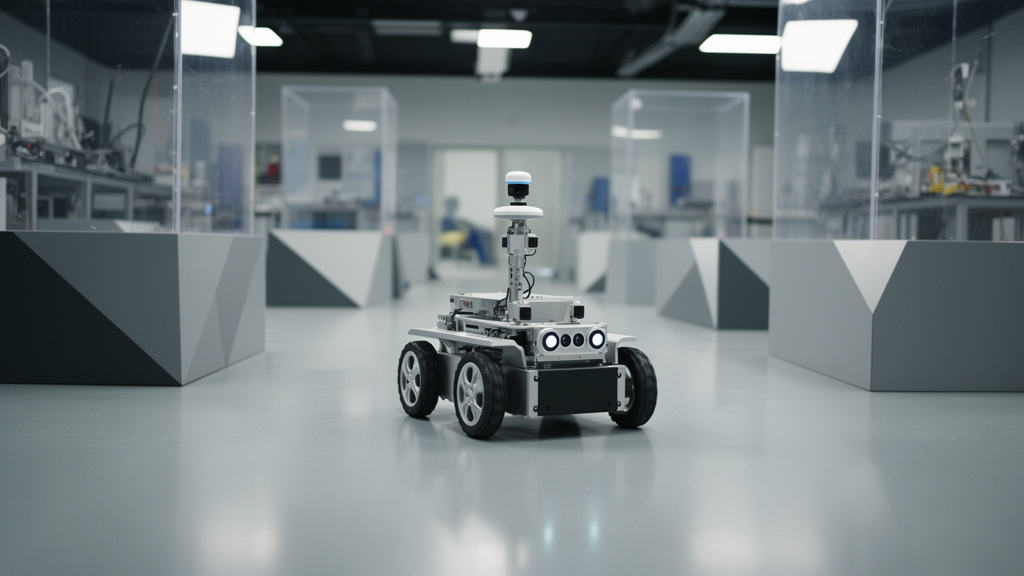
An improved Tornado Optimizer incorporating Coriolis force mechanisms matched the shortest path identified by Dijkstra’s algorithm across thirty independent test runs on seven benchmark maps. Developed to enhance mobile robot path planning in autonomous navigation, the modified metaheuristic demonstrated superior search efficiency and reduced path lengths when evaluated against six established baseline algorithms under multiple obstacle configurations.

Autonomous navigation depends heavily on efficient path planning, yet conventional algorithms frequently encounter low search efficiency or become trapped in local optima when deployed in complex operating environments. To address these operational constraints, researchers Yuhang Cen and Xinsheng Lai designed the improved Tornado Optimizer with Coriolis force, designated as ITOC, which integrates targeted modifications into initial population sampling, subgroup mutation probabilities, and directional search operations.

During the population initialization phase, the algorithm incorporates a good point set method to establish well-distributed initial candidate trajectories across the search area. The procedure generates prime numbers calibrated specifically to the obstacle density measured within each column of the environmental grid map, thereby systematically increasing the diversity of initial solutions before iterative optimization commences.

To manage the transition between global exploration and local exploitation, ITOC establishes differentiated mutation trigger probabilities across three distinct functional sub-populations: storm, thunderstorm, and tornado. By tailoring the probability of mutation according to the specialized behavioral role assigned to each subgroup, the optimization framework prevents premature convergence while maintaining focused refinement near promising trajectory candidates.

The mutation mechanism computes an intersection point on the current grid column using a line connecting the target point with the preceding column’s selected coordinates. ITOC samples replacement candidates from a Gaussian probability distribution centered directly on this calculated intersection, while applying an attenuation factor tied to the slope direction of the connecting line to suppress candidates that deviate from the destination, guiding mutations consistently toward the target.

The researchers verified the algorithm through comparative benchmark experiments against six optimization baselines: the original Tornado Optimizer, an improved genetic algorithm, an improved ant colony algorithm, differential evolution, particle swarm optimization, and the JAYA algorithm. Evaluated across two obstacle densities and a literature-standard benchmark map, the algorithm demonstrated consistent convergence, securing the exact shortest path length in all independent test iterations.

Subject of Research: Mobile robot path planning using an improved Tornado Optimizer with Coriolis force

Article Title: Mobile robot path planning based on an improved Tornado Optimizer

Article References: Cen, Y., & Lai, X. (2026). Mobile robot path planning based on an improved Tornado Optimizer. Discover Applied Sciences. https://doi.org/10.1007/s42452-026-09789-2

Image Credits: AI Generated

DOI: 10.1007/s42452-026-09789-2

Keywords: mobile robot path planning, autonomous navigation, Tornado Optimizer, Coriolis force, ITOC algorithm, good point set method, prime numbers, obstacle density, grid map, Gaussian probability model, attenuation factor, Dijkstra algorithm, genetic algorithm, ant colony algorithm, differential evolution, particle swarm optimization, JAYA algorithm, global exploration, local exploitation

News Source: Denise Maddox. (November 11, 2026). Improved Tornado Optimizer Matches Dijkstra Shortest Path in Robot Navigation Tests. Scienmag.
Tags: ant colony algorithmattenuation factorAutonomous NavigationCoriolis forcedifferential evolutionDijkstra algorithmGaussian probability modelgenetic algorithmglobal explorationgood point set methodgrid mapITOC algorithmJAYA algorithmlocal exploitationmobile robot path planningobstacle densityparticle swarm optimizationprime numbersTornado Optimizer
Share12Tweet7Share2ShareShareShare1

Related Posts

Virtual Semantic Knowledge Graphs and Negative Feedback Enhance Recommender System Accuracy

Virtual Semantic Knowledge Graphs and Negative Feedback Enhance Recommender System Accuracy

November 11, 2026
Localized Neural Network Cuts PET Image Blurring and Shortens Scan Times

Localized Neural Network Cuts PET Image Blurring and Shortens Scan Times

November 11, 2026

Review Evaluates Construction Noise Risks for Endangered Baltic Harbour Porpoises

November 11, 2026

Polytrauma Caregiver Burden Decreases Significantly Over Six Months Following Hospital Discharge

November 11, 2026

POPULAR NEWS

  • Waist-to-Height Glucose Index Predicts Mortality Across Cardiovascular-Kidney-Metabolic Stages

    Waist-to-Height Glucose Index Predicts Mortality Across Cardiovascular-Kidney-Metabolic Stages

    29 shares
    Share 12 Tweet 7
  • Lower Admission Platelet Mass Index Independently Associates With Preterm Infant Mortality

    29 shares
    Share 12 Tweet 7
  • Canadian Pediatric Case Documents Atypical Vernal Keratoconjunctivitis and Long-Term Resolution

    29 shares
    Share 12 Tweet 7
  • Micronutrients Counteract Liver Gene Methylation in Female Offspring of Diabetic Rats

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Photon-Counting CT Has Potential to Enhance Abdominal Tumor Detection and Treatment Assessment

Four LncRNAs Show Elevated Expression Across Diffuse Large B-Cell Lymphoma Subtypes

Potato Cultivars Show Distinct Metabolic Shifts Under Fungal Infection and Toxin Stress

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 87 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.