In camera-based wireless networked control systems, mobile robots must stream visual data across a shared radio link before navigation commands can be generated and applied to drive actuators. Because communication delays and computational workloads jointly dictate how quickly sensory observations translate into physical motion, deciding where to partition perception between onboard processors and remote servers represents a critical engineering challenge. A study by researchers Junyeong Jeon, Daniel Poul Mtowe, and Dong Min Kim at Soonchunhyang University, published in Frontiers in Robotics and AI, demonstrates that this payload-freshness relationship does not vary smoothly across computational cut points. Instead, physical robotic evaluations reveal a sharp saturation knee at the very first edge-processing cut. By executing initial image filtering and contour extraction directly on the robot, the system eliminates ninety-five point six percent of raw transmission payload while securing between ninety-six point six and ninety-nine point six percent of the total freshness improvement achievable across the processing chain.
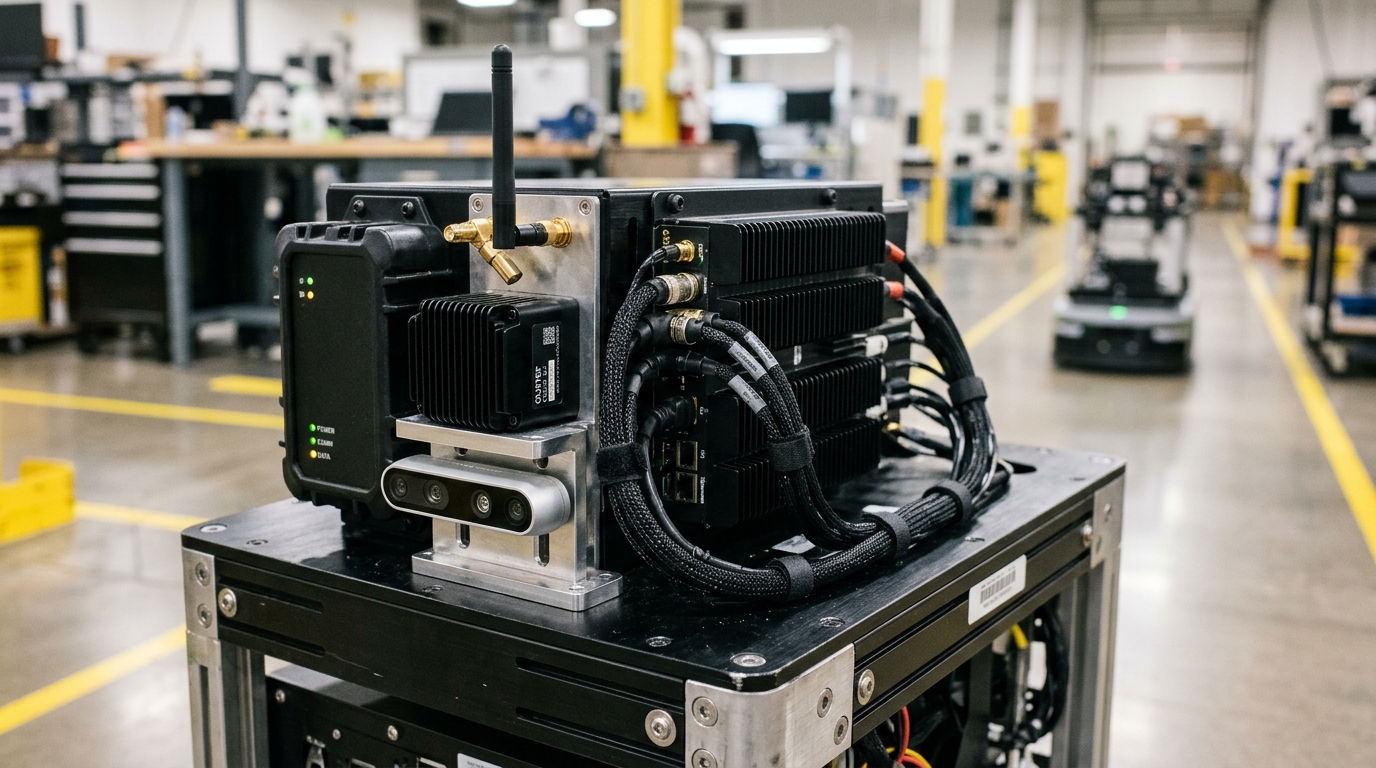
The researchers tested this phenomenon on a physical robotic testbed operating within a closed-loop trajectory-following setting. The experimental vehicle was a differential-drive robot powered by a single-board Raspberry Pi computer featuring a one point four gigahertz quad-core ARM Cortex-A53 processor and one gigabyte of memory, equipped with an optical camera capturing frames at one hundred sixty by one hundred twenty pixel resolution. Actuation commands drove the platform via general-purpose input-output connections linked to a dual-channel motor driver. The robot communicated over a five gigahertz Wi-Fi network to an access point wired through Gigabit Ethernet to a remote workstation containing an Intel Core i7-9700K processor and sixteen gigabytes of memory. To isolate computation placement, the remote server executed the path-tracking controller across all trials. The system implemented a discrete proportional-integral-derivative control law with fixed gains of zero point four five, zero point zero one, and zero point zero five, referencing an eighty-pixel center coordinate to guide line-following motion.
The team investigated four distinct computation-offloading configurations spanning more than four orders of magnitude in transmitted data size. In the centralized reference mode, termed PUPPET, the robot performed no onboard vision processing, streaming complete raw frames of sixty-one thousand five hundred seventy bytes requiring forty-three transmission control protocol segments per update. In Edge Level 1, the robot executed grayscale conversion, Gaussian smoothing, binary thresholding, and contour extraction locally, transmitting serialized contour coordinates averaging two thousand six hundred ninety-four bytes across two segments. In Edge Level 2, the onboard processor calculated spatial contour moments, transmitting a compact three-hundred-ninety-byte feature representation within a single segment. Finally, Edge Level 3 performed complete road-center extraction on the mobile chassis, sending only a four-byte scalar coordinate in one segment. In every configuration, the remote server received updates, evaluated the steering law, and dispatched a standardized forty-six-byte command back to the robot. Moving from Edge Level 1 to Edge Level 3 reduced transmitted bytes by six hundred seventy-four-fold.
To evaluate true temporal staleness rather than transit delay alone, the researchers measured actuation-side Age of Information, defined as the time elapsed since the capture of the camera observation currently governing physical wheel movement. Reconstructing this metric entirely from timestamps generated by the robot’s internal monotonic clock eliminated cross-device synchronization uncertainty. The experimental campaign evaluated these modes under two controlled uplink channel conditions applied to outbound traffic. The Good channel profile featured a thirty megabit per second bandwidth cap, six milliseconds of added round-trip delay, and one millisecond of jitter. The Bad channel profile imposed a fifteen megabit per second cap, twelve milliseconds of added delay, and one millisecond of jitter. Operating across eighty individual one-hundred-twenty-second trials, transmission control protocol ensured that zero packets were dropped, while zero deadline misses occurred against a three-hundred-millisecond timeout. The experimental framework therefore created a controlled delay regime where freshness differences reflected processing placement and service times without confounding packet loss.
Timing decompositions revealed that wireless network service overwhelmingly dictated command transaction durations, whereas onboard computational costs remained minor across all edge configurations. Under Good channel conditions, network transit time fell from twenty-four point one nine milliseconds in PUPPET to ten point six two milliseconds in Edge Level 1, while Bad channel conditions produced a drop from forty-five point nine eight milliseconds to sixteen point five nine milliseconds. Progressing further from Edge Level 1 to Edge Level 3 altered network duration by only zero point three four milliseconds under Good conditions and zero point three two milliseconds under Bad conditions. Total generation-to-actuation transaction times exhibited an identical pattern, falling by thirteen point nine seven milliseconds and twenty-nine point seven three milliseconds between PUPPET and Edge Level 3 across the respective channels. Meanwhile, robot-side perception execution consumed only zero point five five to zero point six one milliseconds in edge modes, an expenditure largely balanced by reductions in server processing and handoff overhead.
Continuous-time evaluations of actuation-side Age of Information demonstrated that average freshness benefits saturate sharply once the raw image is eliminated from the link. Under Bad channel conditions, mean actuation age dropped from eighty-two point seven three milliseconds in PUPPET to forty-four point seven five milliseconds in Edge Level 3, representing a thirty-seven point nine seven millisecond total reduction. Crucially, Edge Level 1 achieved a mean age of forty-five point two six milliseconds, capturing thirty-seven point four seven milliseconds, or ninety-eight point seven percent, of that entire improvement. Advancing from Edge Level 1 to Edge Level 3 yielded a further improvement of merely zero point five zero milliseconds. Under Good channel conditions, total mean age decreased by fifteen point zero eight milliseconds between PUPPET and Edge Level 3, with Edge Level 1 delivering fourteen point five seven milliseconds of the benefit. Once visual data was converted into an extracted contour, massive further payload reductions provided negligible gains in average actuation timeliness.
Rigorous statistical testing confirmed that this flattening represents a genuine saturation in magnitude rather than an inability to resolve fine temporal variations. Applying Welch two-sample tests with Holm multiplicity adjustments across edge contrasts demonstrated that the small residual improvements remained statistically detectable. Under Bad channel conditions, the step reductions of zero point two eight five milliseconds between Edge Levels 1 and 2 and zero point two one eight milliseconds between Edge Levels 2 and 3 yielded adjusted p-values of zero point zero one one. Across all channel combinations, the net Edge Level 1 to Edge Level 3 reduction was statistically significant with adjusted p-values of at most zero point zero zero nine. However, this residual step was between twenty-eight and two hundred sixty-nine times smaller than the initial PUPPET to Edge Level 1 transition. The approximately half-millisecond residual gain represented roughly one percent of the camera’s fifty-two point zero seven millisecond sampling interval, confirming a distinct saturation knee.
The penalty of raw-image transmission proved far more severe in the statistical tail of actuation freshness than in average metrics. Under Bad channel conditions, ninety-fifth percentile actuation Age of Information for PUPPET escalated to two hundred eight point seven three milliseconds, compared to sixty-eight point seven three milliseconds for Edge Level 3, representing a three-fold disparity. Under Good channel conditions, PUPPET reached eighty-eight point seven eight milliseconds against sixty-two point three six milliseconds for Edge Level 3. Execution logs revealed that this tail inflation stemmed from loop scheduling dynamics rather than communication loss. Because raw-image transactions frequently occupied extended durations—averaging trial peaks of two hundred nineteen point eight milliseconds—the robot’s control loop was occupied when subsequent camera frames arrived, causing frames to be skipped. Skipped frame rates reached four point zero nine percent in Bad-channel PUPPET compared to roughly one percent in edge modes, depressing effective frame consumption to eighteen point three eight hertz. Transmitting raw images therefore penalized freshness twice: through extended serialization delays and loop desynchronization.
A dedicated closed-loop navigation campaign confirmed that the saturation knee observed in temporal freshness translated directly into physical steering precision. Evaluating line-following stability under the constrained Bad channel across ten trials per mode showed that root-mean-square tracking error dropped from forty-nine point five one pixels in PUPPET to twenty-five point three zero pixels in Edge Level 1. Edge Levels 2 and 3 achieved root-mean-square errors of twenty-four point nine four and twenty-four point four zero pixels, respectively. Edge Level 1 thus secured twenty-four point two one pixels, or ninety-six point four percent, of the total error reduction. Ninety-fifth percentile tracking errors exhibited the same trajectory, dropping from sixty-seven point eight zero pixels in PUPPET to twenty-nine point two nine pixels in Edge Level 1, while line detection availability rose from seventy-four point six percent to ninety-four point eight percent. Frequent line loss in PUPPET reflected vehicle drift caused by stale steering commands, demonstrating that actuation-side age directly governs dynamic path-following fidelity.
Extending these single-robot empirical measurements to multi-robot deployments revealed that shared-medium scalability, actuation freshness, and transmitted byte volume follow three fundamentally divergent exhaustion patterns. An analytical airtime model incorporating fixed link-layer overheads under an eighty percent channel utilization budget demonstrated that frame counts govern scalability once packets become compact. A single PUPPET robot consumed thirty-six point three six percent of the medium across its forty-three segments, precluding multi-robot operation. In contrast, Edge Level 1 reduced transmission to two segments, enabling thirty concurrent robots. Edge Levels 2 and 3 fit within single segments, supporting forty-nine and fifty-three robots, respectively. Moving from Edge Level 1 to Edge Level 3 supported only one point seven seven times more robots despite a six-hundred-seventy-four-fold reduction in transmitted bytes. While actuation freshness saturates at the first cut, sustainable robot density exhibits diminishing returns through the second cut, and byte volume continues dropping indefinitely. System architects must therefore match offloading depth to the binding operational constraint rather than assuming smaller payloads are uniformly better.
Subject of Research: Actuation-side information freshness and computation offloading in networked mobile robotics
Article Title: Computation offloading and information freshness in edge-assisted networked robotic systems
Article References: Jeon, J., Mtowe, D. P., & Kim, D. M. (2026). Computation offloading and information freshness in edge-assisted networked robotic systems. Frontiers in Robotics and AI, 13, Article 1999591. https://doi.org/10.3389/frobt.2026.1999591
Image Credits: AI Generated
DOI: 10.3389/frobt.2026.1999591
Keywords: robotics, edge computing, Age of Information, wireless networked control, computation offloading, mobile robots, information freshness, autonomous navigation, Computation, offloading, information, freshness
News Source: Denise Maddox. (November 7, 2026). Edge Preprocessing Saturates Information Freshness in Networked Mobile Robot Systems. Scienmag.