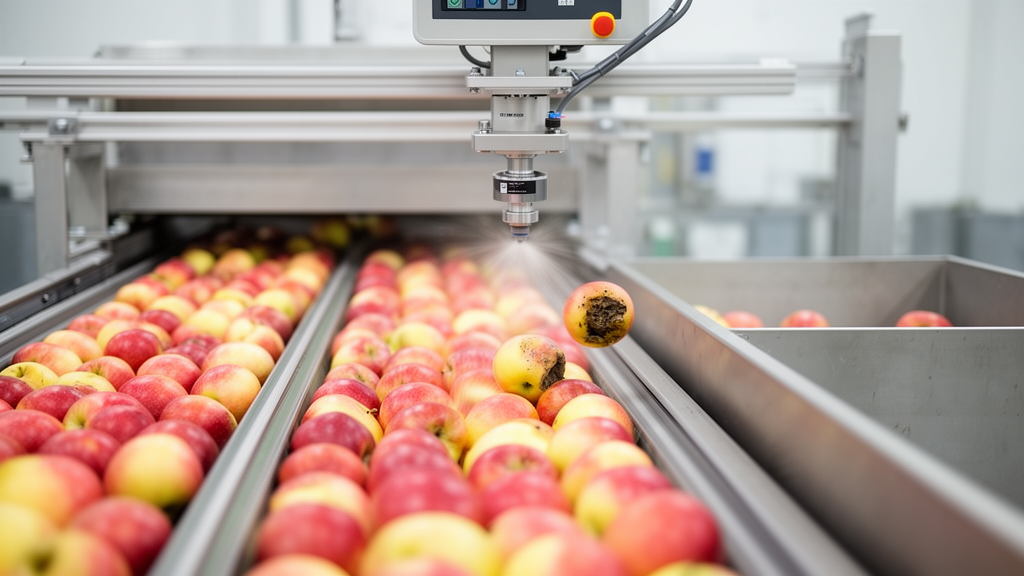
Sorting machines that could curb these losses are expensive and largely designed for large-scale packhouses, so many smaller operations continue to depend on manual inspection. Against this backdrop, researchers have assembled a lightweight machine-vision prototype that inspects apples travelling along three parallel lanes with a single industrial camera, flags surface defects, and ejects defective fruit before the apples continue downward for size grading. The pipeline couples a streamlined object-detection transformer with a simplified multi-object tracker and a trajectory-confirmation rule that turns perception into precisely timed ejection commands.
The prototype's layout mirrors the sequence of decisions an apple must undergo. Defect detection and upper-layer ejection come first; size grading is handled below. Because the entire vision pipeline runs on one camera covering three lanes, the design avoids per-lane cameras and keeps the compute budget small enough for real-time deployment.
The authors describe the system in the journal Artificial Intelligence in Agriculture, positioning it as a perception and decision framework rather than a standalone detector: the same trajectory information that stabilizes tracking also drives the ejection logic. At the core of the detector sits MOD-DETR, a network built on the RT-DETR architecture. The team streamlined the convolution designs, added multi-scale context modeling, and kept the model lightweight.
On their apple defect dataset, MOD-DETR reached a mean average precision at an IoU threshold of 0.5 (mAP@50) of 86.7 percent, with precision of 90.7 percent and an F1-score of 85.7, while requiring 28.9 GFLOPs and running at 95.4 frames per second on an RTX 4090 GPU. The authors argue that this balance between accuracy and model complexity matters more than raw speed for deployment on modest hardware, where a heavier network would either miss the real-time budget or sacrifice accuracy. Baselines trained under identical settings put the trade-off in perspective.
YOLOv8s ran faster at 230.8 FPS but scored 5.3 percentage points lower on mAP@50, while YOLOv11m matched accuracy only at more than double the computational cost. Across three random seeds, the defect-only mean AP@50 rose from 80.36 to 82.29 percent, with bruise improving the most at 2.85 percentage points. The largest gains appeared for defects that are easily overshadowed by fruit-surface texture, which the streamlined designs and multi-scale context modeling were intended to address.
Detection alone cannot eject an apple; the system must know which detections belong to which trajectory. For this, the team built ASORT, a tracker based on the SORT framework. Because apples on the line look highly similar and their motion is dictated by the fruit-cup conveying mechanism, complex appearance modeling and re-identification features offer little benefit.
ASORT instead uses simplified state estimation with a constant-velocity motion model, filters apple detections at a confidence threshold of 0.9 while retaining weaker defect detections above 0.3, and associates frames by fusing box overlap with a velocity-consistency score computed from the cosine similarity between current displacement and historical trajectory velocity. Trajectory lifecycle management confirms a track only after a minimum number of consecutive frames and removes it after a maximum number of unreachable frames. On the annotated sorting video, ASORT achieved 97.6 percent MOTA and 98.8 percent IDF1 at 19.7 FPS, cutting false negatives from 101 to 46 and fragmentation from 9 to 4 relative to SORT, with no identity switches.
It outperformed ByteTrack, StrongSORT, HybridSORT and DeepOCSORT when all methods ran on the same detections. The authors attribute the gains to the velocity-consistency fusion, which stabilizes association when apples are closely spaced, and to the lifecycle rule, which suppresses short-lived false tracks. Perception then had to become action.
The team introduced a trajectory-confirmation mechanism in which a track is declared defective once the cumulative number of defect-positive observations associated with it reaches a threshold K. Testing on production-line videos of 398 apples, including 335 defective and 63 normal samples, showed the trade-off clearly: with K equal to 1, no defective apple was missed but 36.51 percent of normal apples were falsely rejected; with K equal to 3, false rejections fell to 7.94 percent but 5.37 percent of defective fruit slipped through. K equal to 2 maintained zero missed rejections, reduced false rejections to 9.52 percent, and achieved the highest decision accuracy of 98.49 percent, so it was selected for the online test. The online validation exposed both the promise and the limits of the approach.
With the conveyor running at 0.16 meters per second and the paddle's open-close cycle measured at 0.6 seconds, corresponding to roughly 96 millimeters of conveyor travel per cycle, tightly spaced apples could reach the rejection position before the paddle fully returned. Of the 200 test apples, divided into four size classes of 50 each, the system's 15.0 percent missed rejection rate, driven by 12 missed defective fruit, far exceeded its 2.5 percent false rejection rate. The authors attribute this to the short distance between the paddle sorter and the fruit-cup unit, fruit spacing and pneumatic response delay.
The authors caution that validation covered a fixed imaging configuration and a limited operating range. Edge-of-image apples, where object scale shrinks further under long-range imaging, remain difficult for the detector. Broader testing across conveyor speeds, cultivars and operating conditions is still needed before the threshold strategy's operating boundary can be defined.
Within those limits, the prototype demonstrates that a single camera, a streamlined transformer and a simplified tracker can carry defect detection, tracking and timed ejection across three lanes in real time.
Subject of Research: Lightweight single-camera, three-lane machine vision and decision framework for online apple surface-defect sorting
Article Title: A lightweight perception and decision framework for single-camera three-lane online apple defect sorting
Article References: Qiao, P., Chen, G., Li, Z., Hao, J., Tang, W., Liu, Y., & Tchuenbou-Magaia, F. (2026). A lightweight perception and decision framework for single-camera three-lane online apple defect sorting. Artificial Intelligence in Agriculture. https://doi.org/10.1016/j.aiia.2026.09.009
Image Credits: AI Generated
DOI: 10.1016/j.aiia.2026.09.009
Keywords: apple sorting, machine vision, defect detection, object detection transformer, multi-object tracking, lightweight deep learning, agricultural robotics, post-harvest grading, RT-DETR, pneumatic sorting, precision agriculture, computer vision
News Source: Blake Davidson. (October 23, 2026). One Camera, Three Lanes: Lightweight AI Prototype Detects and Ejects Defective Apples in Online Sorting Test. Scienmag.