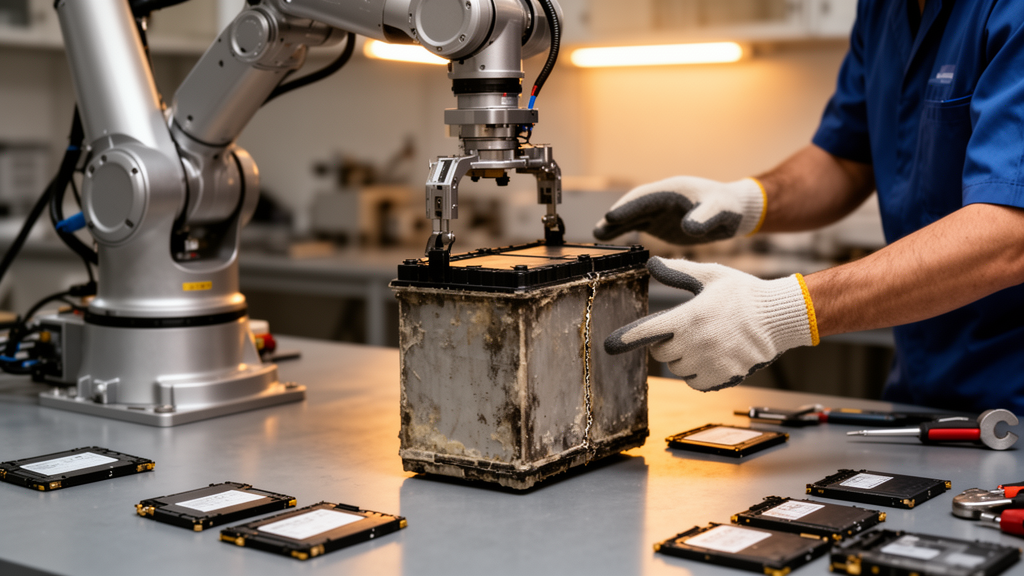
Robots are increasingly being asked to take apart products that were never designed for disassembly, and few tasks illustrate the challenge better than dismantling spent electric-vehicle batteries. A research team reporting in Frontiers in Robotics and AI has now built an AI planning system that lets a robot dismantle such batteries while keeping a human operator firmly in the loop, and the results show measurable gains in both planning accuracy and operator efficiency.
The core difficulty is that planning quality depends on translating noisy camera data into a reliable sequence of actions. The system derives each object’s position from live depth imagery, converts those detections into structured scene text, and then asks a large language model to produce an ordered removal plan. Every plan must satisfy three conditions: it must be complete, it must respect physical constraints such as removing obstructing parts before the parts they block, and it must never reference objects that do not actually exist in the scene.
To keep the model honest, the researchers layered multiple safeguards around it. A generator model produces a candidate plan under a strict list-only output rule that forbids explanations, headings, or bullets. A separate verifier model then re-checks the candidate against the same scene representation, validating format, duplicates, and ordering. Finally, a deterministic grounding filter strips out any line whose label and coordinates cannot be matched to a detected object, guaranteeing that hallucinated parts never reach the robot.
The upgraded version replaces the earlier ensemble approach, which sampled multiple candidate plans and required six generator calls plus one verifier call, with a single generator call and, when needed, one verifier call. The model was also given a more structured reasoning prompt and a clearer set of matching rules for interpreting user requests, including how to handle ambiguous references and when to declare that no valid target exists.
On the offline benchmark, the single-call generator already achieved strong results, and adding the verifier and grounding filter pushed full-plan accuracy to 96.5 percent, up from 82.4 percent for the earlier ensemble pipeline with the same replacement model. The researchers stress that these figures come from a constrained benchmark and may overstate performance on unseen battery layouts or unfamiliar operator phrasing.
The team also built a fully integrated web interface that streams live camera views, clickable object detections, and every intermediate planning stage to the operator. Users can inspect the structured input, the generator output, the verifier output, and the final filtered plan, then accept or reject the result. In a pilot study with twelve participants, the new interface cut the average time to accept a plan from 22 seconds to 15 seconds on the first task and from 15 seconds to 11 seconds on the second, while retrospective workload scores dropped from 24.1 to 14.1 on a 100-point scale. Every participant preferred the new interface.
The researchers caution that the pilot was small and exploratory, that planning quality is tied to the accuracy of the underlying perception, and that the deterministic filter can reject valid plans whose formatting or coordinates deviate from expectations. They also note that the results are tied to one specific model and do not establish model-agnostic performance. Future work will focus on broader benchmarks, richer scene representations, and testing across multiple language models under identical prompts and scoring rules.
The benchmark underlying these findings deserves closer attention, because it explains why the accuracy numbers can be compared cleanly across pipeline versions. The evaluation set consists of 200 distinct scenes, each paired with three operator intents, yielding 600 planning episodes in total. Because every version of the system was run against the same episodes, the reported gains reflect changes to the planning architecture rather than differences in task difficulty. The metric, mean full-list correctness, is deliberately strict: a plan counts as correct only if every removal step is present, properly ordered, and grounded in the scene, so partial credit is not awarded for plans that are merely plausible.
Viewed through that lens, the progression of scores traces a clear engineering narrative. The earlier six-sample ensemble pipeline, which sampled multiple candidate plans from a single model checkpoint and reconciled them through verification, reached a mean full-list correctness of 0.824. Simply swapping in the replacement language model while keeping the ensemble machinery intact raised the figure to 0.896, indicating that a substantial share of the improvement came from the stronger instruction-following behavior of the newer model rather than from the ensemble structure itself. The upgraded configuration, which discarded parallel sampling in favor of a single generator call with revised prompts, reached 0.935 on its own, and the addition of the verifier stage and the deterministic grounding filter lifted the final figure to 0.959.
That the upgraded generator alone outperformed the full prior pipeline is notable, because it suggests that prompt design and output contracts can matter as much as model choice. The revised generator prompt emphasizes strict list formatting, explicit handling of ambiguous references, and clear rules for declaring when no valid target exists, which reduces the formatting drift that previously had to be repaired downstream. The verifier then operates on a shared formal grammar with the generator, so both stages agree on what constitutes a well-formed plan, and the verifier can correct ordering errors or duplicates before the deterministic filter performs its final token-level check against the perceived scene payload.
The reduction in language model calls from seven to two carries practical consequences beyond accuracy. Each call adds latency, compute cost, and another opportunity for the model to introduce inconsistencies, so halving the call count while improving correctness represents a genuine efficiency gain rather than a trade-off. For deployment settings such as battery recycling facilities, where operators wait on the planner between actions, fewer calls translate directly into shorter planning cycles and lower per-plan operating expense.
The human factors results, though drawn from a small within-subject pilot, align with a broader principle in human-robot interaction research: operators trust and use automated planning tools more effectively when they can see what the system is reasoning about. By streaming the exact text sent to each model stage and displaying raw, cleaned, verified, and filtered plans side by side, the interface turns the planner from a black box into an inspectable artifact. The consistent preference of all twelve participants, together with lower raw NASA-TLX workload scores and faster acceptance times on both tasks, suggests that transparency did not come at the cost of added cognitive burden, which is often a concern when interfaces expose internal system states.
The LUZD coordinate representation also plays a quiet but important role in the pipeline. Depth cameras produce point clouds in a sensor frame that can shift as the camera moves, so plans expressed in raw sensor coordinates are fragile. By rewriting all detections into a frame-consistent representation, the system ensures that the labels and coordinates the language model reasons over match what the deterministic filter later checks, and that accepted plans can be executed by the robot without an additional coordinate reconciliation step.
It is worth situating the anti-hallucination filter within the wider literature on hallucination mitigation. Sampling-based consistency checks such as SelfCheckGPT estimate reliability by comparing multiple generated outputs, which is effective but expensive. In robotic settings, where every emitted action may be physically executed, a deterministic post hoc filter that enforces exact input-output consistency is attractive precisely because it is cheap, predictable, and auditable. The trade-off, acknowledged by the authors, is that such filters can reject valid plans whose formatting or coordinates deviate from expectations, so filter strictness must be balanced against unnecessary plan rejection.
The application domain itself shapes many of these design choices. Electric-vehicle batteries arrive at end-of-life in highly variable states: pack designs differ across manufacturers, fasteners and modules may be corroded or deformed, and prior partial disassembly can leave the scene in unexpected configurations. Technoeconomic analyses of battery recycling consistently identify this uncertainty, together with non-standardized designs, as a barrier to full automation, which is why human-in-the-loop architectures remain prominent in the field. A planner that can accept natural-language corrections from an operator, while guaranteeing through deterministic grounding that no phantom component enters the action list, fits that operational reality better than either fully manual teardown or fully autonomous scheduling.
Finally, the authors are careful to bound their claims. The benchmark scenes are constrained, the pilot cohort is small, and the results are tied to one specific model checkpoint, so the findings should be read as evidence that structured scene text, clear prompts, verifier-based correction, deterministic grounding, and inspectable interfaces form a productive combination, rather than as proof that any language model would perform equivalently. The stated agenda of testing multiple models under identical prompts and scoring rules, and of extending the scene representation beyond current limits, points toward the kind of controlled comparisons that will determine whether these gains generalize across the messy variety of real disassembly floors.
Subject of Research: Robotics and AI
Article Title: Interactive and inspectable LLM planning for human-in-the-loop EV battery disassembly
Article References: Interactive and inspectable LLM planning for human-in-the-loop EV battery disassembly. (n.d.). https://doi.org/10.3389/frobt.2026.1916454
Image Credits: AI Generated
DOI: 10.3389/frobt.2026.1916454
Keywords: robotics, AI, EV batteries, disassembly planning, human-robot interaction, large language models, Frontiers in Robotics and AI, Interactive, inspectable, planning, human-in-the-loop, battery
News Source: Denise Maddox. (October 15, 2026). AI System Teaches Robots to Dismantle Dead Batteries With Human Help. Scienmag.